Xinjie Liu
Ph.D. Student · UT Austin · Robot Learning

Hello and welcome! I am a fourth-year Ph.D. student in Electrical and Computer Engineering at The University of Texas at Austin. I am co-advised by Ufuk Topcu and David Fridovich-Keil. I obtained a master’s degree in Robotics with the highest distinction (cum laude) from the Delft University of Technology, the Netherlands, where I was advised by Javier Alonso-Mora. Before that, I received a bachelor’s degree in Automotive Engineering from Tongji University, Shanghai.
I develop algorithms and theory for scalable, sample-efficient, and trustworthy robot learning. Examples of my work include:
-
Multi-fidelity reinforcement learning methods that learn stably from scarce real-robot data, complemented by abundant but imperfect simulation data.
-
Learning behavior models that predict how agents act in interaction-rich, uncertain scenarios.
My research draws on reinforcement learning, game theory, and differentiable optimization, and I ground it in real-world systems such as robotic manipulators and mobile robots.
I am looking for Summer 2027 research internships in reinforcement learning and robot learning. Please feel free to reach out!
publications
-
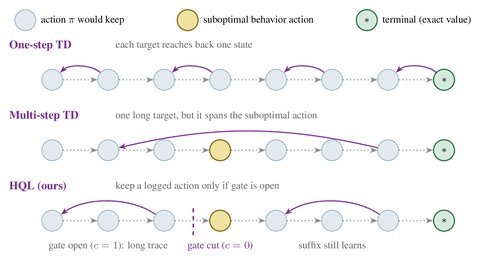 Horizon-Scalable Q-LearningUnder review, 2026
-
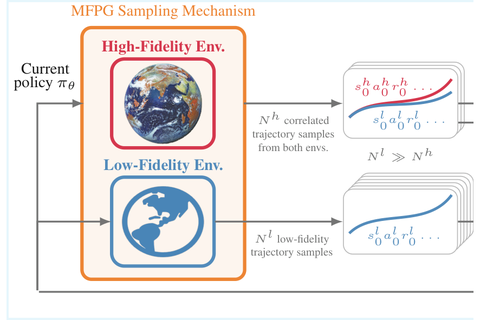 Transactions on Machine Learning Research (TMLR), 2026Awarded J2C Certification (selected to present at NeurIPS 2026)
-
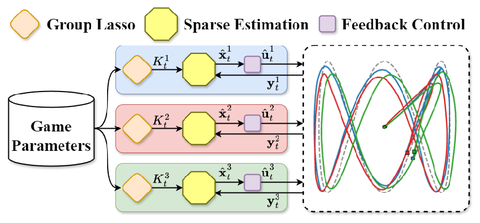 IEEE Control Systems Letters (L-CSS), 2026
-
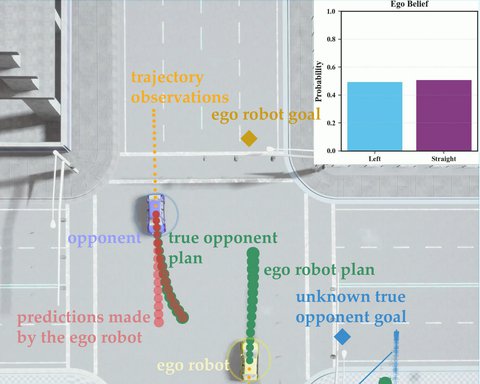 Under review at The International Journal of Robotics Research (IJRR), 2025
-
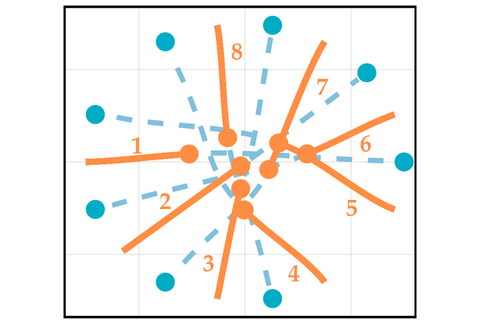 Conditionally accepted at IEEE Transactions on Automatic Control (T-AC), 2025
-
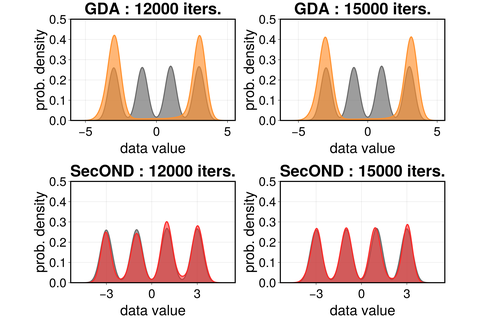 Under review, 2025
-
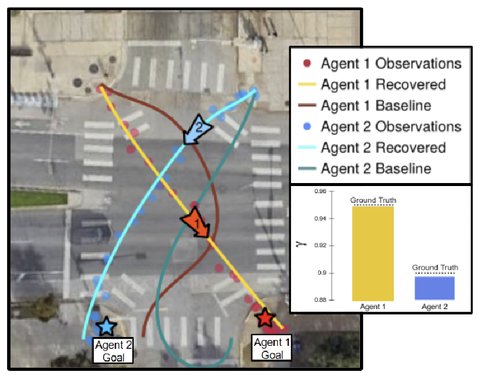 IEEE Robotics and Automation Letters (RA-L), 2025
-
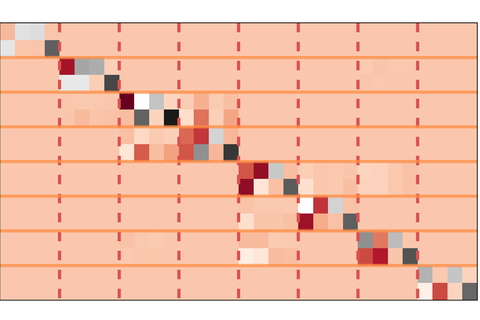 Autonomous Agents and Multi-Agent Systems (AAMAS), Extended Abstract, 2025
-
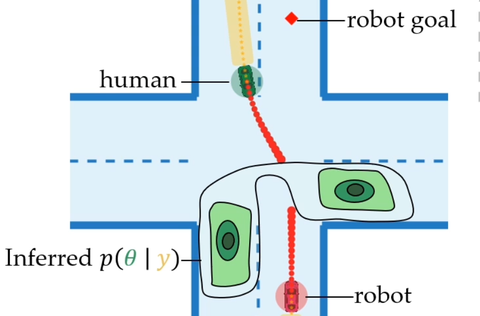 Algorithmic Foundations of Robotics XVI (WAFR), 2024
-
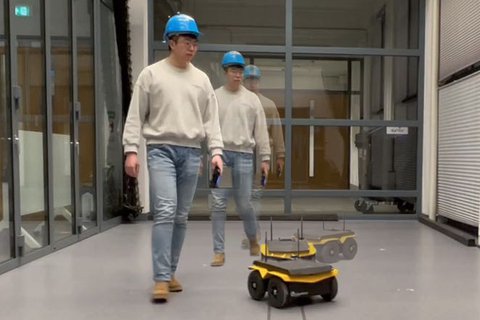 IEEE Robotics and Automation Letters (RA-L), 2023
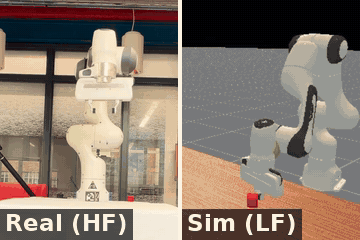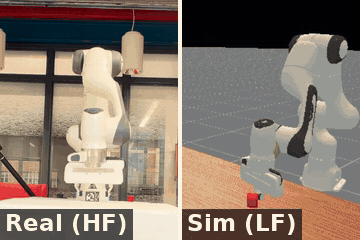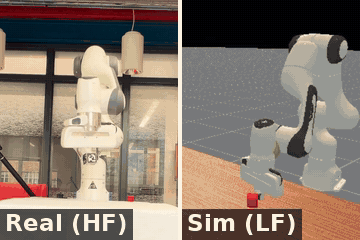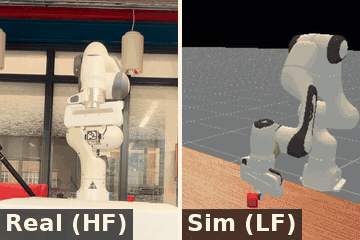
* Equal contribution
news
| Oct 13, 2026 | I will present our TMLR paper “A Multi-Fidelity Control Variate Approach for Policy Gradient Estimation” at the Atlanta venue of NeurIPS 2026 through the Journal-to-Conference (J2C) track! |
|---|---|
| Oct 1, 2026 | Our preprint “Multi-Fidelity Policy Gradients Stabilize Data-Scarce Reinforcement Learning” is out! Our method, MFPG-PPO, learns stably on a physical Franka arm using only 4 real-robot episodes per update. |
| Jun 15, 2026 | Our paper “Linear-Quadratic Gaussian Games with Distributed Sparse Estimation” has been published in the IEEE Control Systems Letters (L-CSS)! |
| Mar 3, 2026 | I gave a talk, “Boosting Reinforcement Learning with Imperfect Data: A Multi-Fidelity Policy Gradient Framework,” at the Texas Symposium on Machine Learning, Responsible AI & Robotics, UT Austin [video]! |
| Feb 11, 2026 | Our paper “A Multi-Fidelity Control Variate Approach for Policy Gradient Estimation” has been accepted to the Transactions on Machine Learning Research (TMLR) and awarded a J2C Certification, selected for presentation at NeurIPS/ICML/ICLR! |
| Dec 27, 2025 | We submitted Bayesian Inverse Games with High-Dimensional Multi-Modal Observations to The International Journal of Robotics Research (IJRR)! |
| Oct 15, 2025 | Our paper “Inferring Foresightedness in Dynamic Noncooperative Games” has been accepted at the IEEE Robotics and Automation Letters (RA-L) and will be presented at ICRA 2026! |
| Sep 29, 2025 | We submitted A Multi-Fidelity Control Variate Approach for Policy Gradient Estimation! |
| May 23, 2025 | I presented Policies with Sparse Inter-Agent Dependencies in Dynamic Games: A Dynamic Programming Approach at AAMAS 2025, Detroit! We submitted an extended version of this work to IEEE Transactions on Automatic Control (T-AC). |
| Apr 11, 2025 | I’m honored to have received a travel grant from Texas Robotics! |
| Oct 16, 2024 | We submitted Policies with Sparse Inter-Agent Dependencies in Dynamic Games: A Dynamic Programming Approach! |
| Oct 9, 2024 | I’m honored to have received a travel grant from WAFR 2024 and to have presented our work Auto-Encoding Bayesian Inverse Games. It was a lot of fun in Chicago! |
| Aug 17, 2024 | Our paper Auto-Encoding Bayesian Inverse Games was accepted to WAFR 2024. See you in Chicago! |
| May 29, 2024 | An open-source project on implementation of numerical optimization algorithms. |
| May 22, 2024 | We submitted Second-Order Algorithms for Finding Local Nash Equilibria in Zero-Sum Games! |
| Feb 2, 2024 | We submitted Auto-Encoding Bayesian Inverse Games! |
| Jul 10, 2023 | Graduated from TU Delft! I successfully defended my thesis and obtained my MSc degree with Cum Laude distinction in Robotics [slides]! |
| Jul 5, 2023 | I gave a talk at the Control and Learning for Autonomous Robotics (CLeAR) Lab, UT Austin! |
| Apr 17, 2023 | Our paper “Learning to Play Trajectory Games Against Opponents with Unknown Objectives” has been accepted at the IEEE Robotics and Automation Letters (RA-L) and will be presented at IROS 2023. See you in Detroit! |
| Jan 24, 2023 | I gave an invited talk at the Safe Robotics Laboratory, Princeton [slides]. Thanks for the invitation! |
| Dec 1, 2022 | Our work “Learning to Play Trajectory Games Against Opponents with Unknown Objectives” has been submitted and is now available! Please check out the preprint version here. |
| Jun 30, 2022 | We won the Hackathon challenge at the European Robotics Forum 2022! (Post from the sponsor Franka Emika) |